


Changhui Jing, Haochen Tian, Hongchen Li, Tianyu Li, Caojun Wang, Zihao Zhang, Yanhao Liu, Chengen Xie, Bailin Li, Hao Zhao, Zhenjie Yang
- 📧 Primary Contact: Changhui Jing (changhui.jing@opendrivelab.com)
- 🖊️ Joint effort by Shanghai Innovation Institute, OpenDriveLab at HKU, Li Auto Inc., Tongji University, and Tsinghua University.
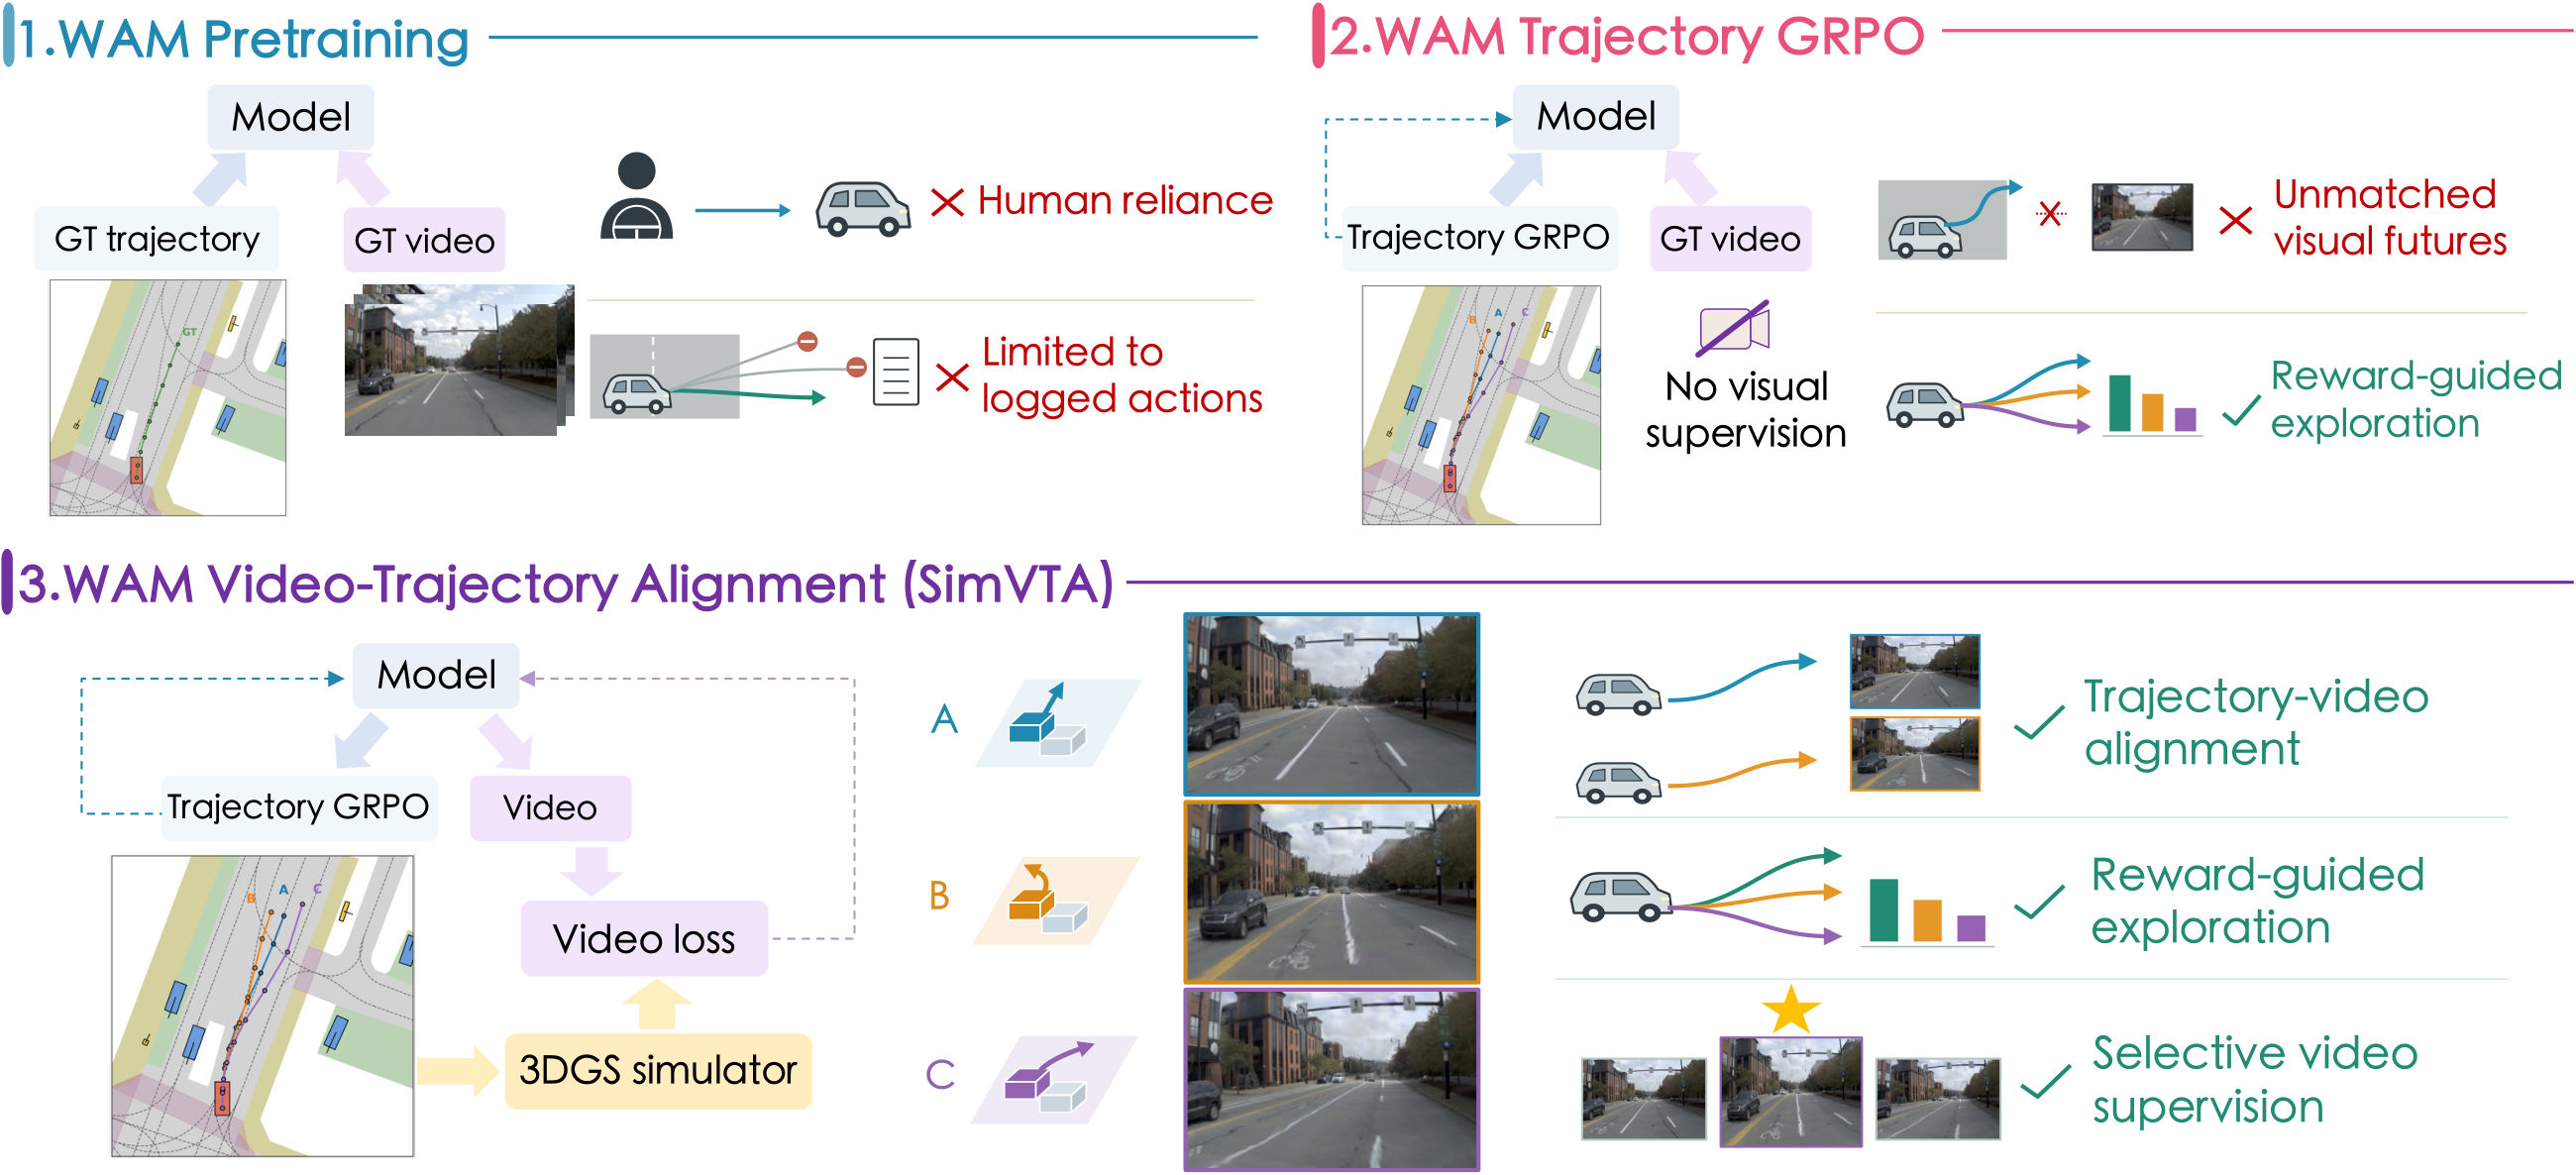
- 🚗 Simulation-grounded alignment: Render matched future videos for alternative candidate trajectories in reconstructed real-world scenes.
- 🔍 Selective video supervision: Prioritize higher-error futures among high-reward candidates and jointly train trajectory planning and video prediction.
- 📈 Improved planning: Achieve 91.3 PDMS on NAVSIM v1, 88.2 EPDMS on NAVSIM v2, and 38.8 average HD-Score on HUGSIM, with direct trajectory prediction at inference.
[2026/10/23]We released the checkpoints and inference code of SimVTA.[2026/10/12]We released our paper on arXiv.
- Results release.
- Checkpoint release.
- Inference and evaluation code.
- Training code.
1. Clone SimVTA
git clone https://github.com/OpenDriveLab/SimVTA.git
cd SimVTA
2. Create Environment
conda create -n simvta python=3.10 -y
conda activate simvta
pip install -r requirements.txt
pip install -e .
Use a CUDA-compatible PyTorch installation and a GPU with bfloat16 support. NAVSIM v1 is included in navsim/.
3. Data Preparation
Prepare the NAVSIM v1 OpenScene navtest logs, sensor blobs, and nuPlan maps following the NAVSIM data instructions. Organize the files as follows:
SimVTA/
├── checkpoints/
│   ├── simvta.pkl
│   └── dcae_td_20000.pkl
├── datasets/
│   ├── maps/
│   │   └── nuplan-maps-v1.0/
│   └── openscene/
│       ├── navsim_logs/
│       │   └── test/
│       └── sensor_blobs/
└── exp/
    └── metric_cache/
4. Download Checkpoints
Download simvta.pkl from OpenDriveLab-org/SimVTA and the temporal-aware DCAE checkpoint dcae_td_20000.pkl from Kevin-thu/Epona. Place both files in checkpoints/:
mkdir -p checkpoints
wget -c https://huggingface.co/OpenDriveLab-org/SimVTA/resolve/main/simvta.pkl -O checkpoints/simvta.pkl
wget -c https://huggingface.co/Kevin-thu/Epona/resolve/main/dcae_td_20000.pkl -O checkpoints/dcae_td_20000.pkl
The DCAE checkpoint encodes the input camera images into latents.
5. NAVSIM Evaluation
bash run/test_navsim.shSimVTA is a simulation-grounded post-training framework for driving world action models. It extends supervision beyond logged trajectories using a 3D Gaussian Splatting simulator, combining trajectory GRPO with a flow-matching video loss that updates shared representations.
Reported results in the paper:
| Benchmark | Metric | SimVTA |
|---|---|---|
| NAVSIM v1 | PDMS | 91.3 (+5.1 over the 86.2 initialization) |
| NAVSIM v2 | EPDMS | 88.2 |
| HUGSIM | Average HD-Score | 38.8 |
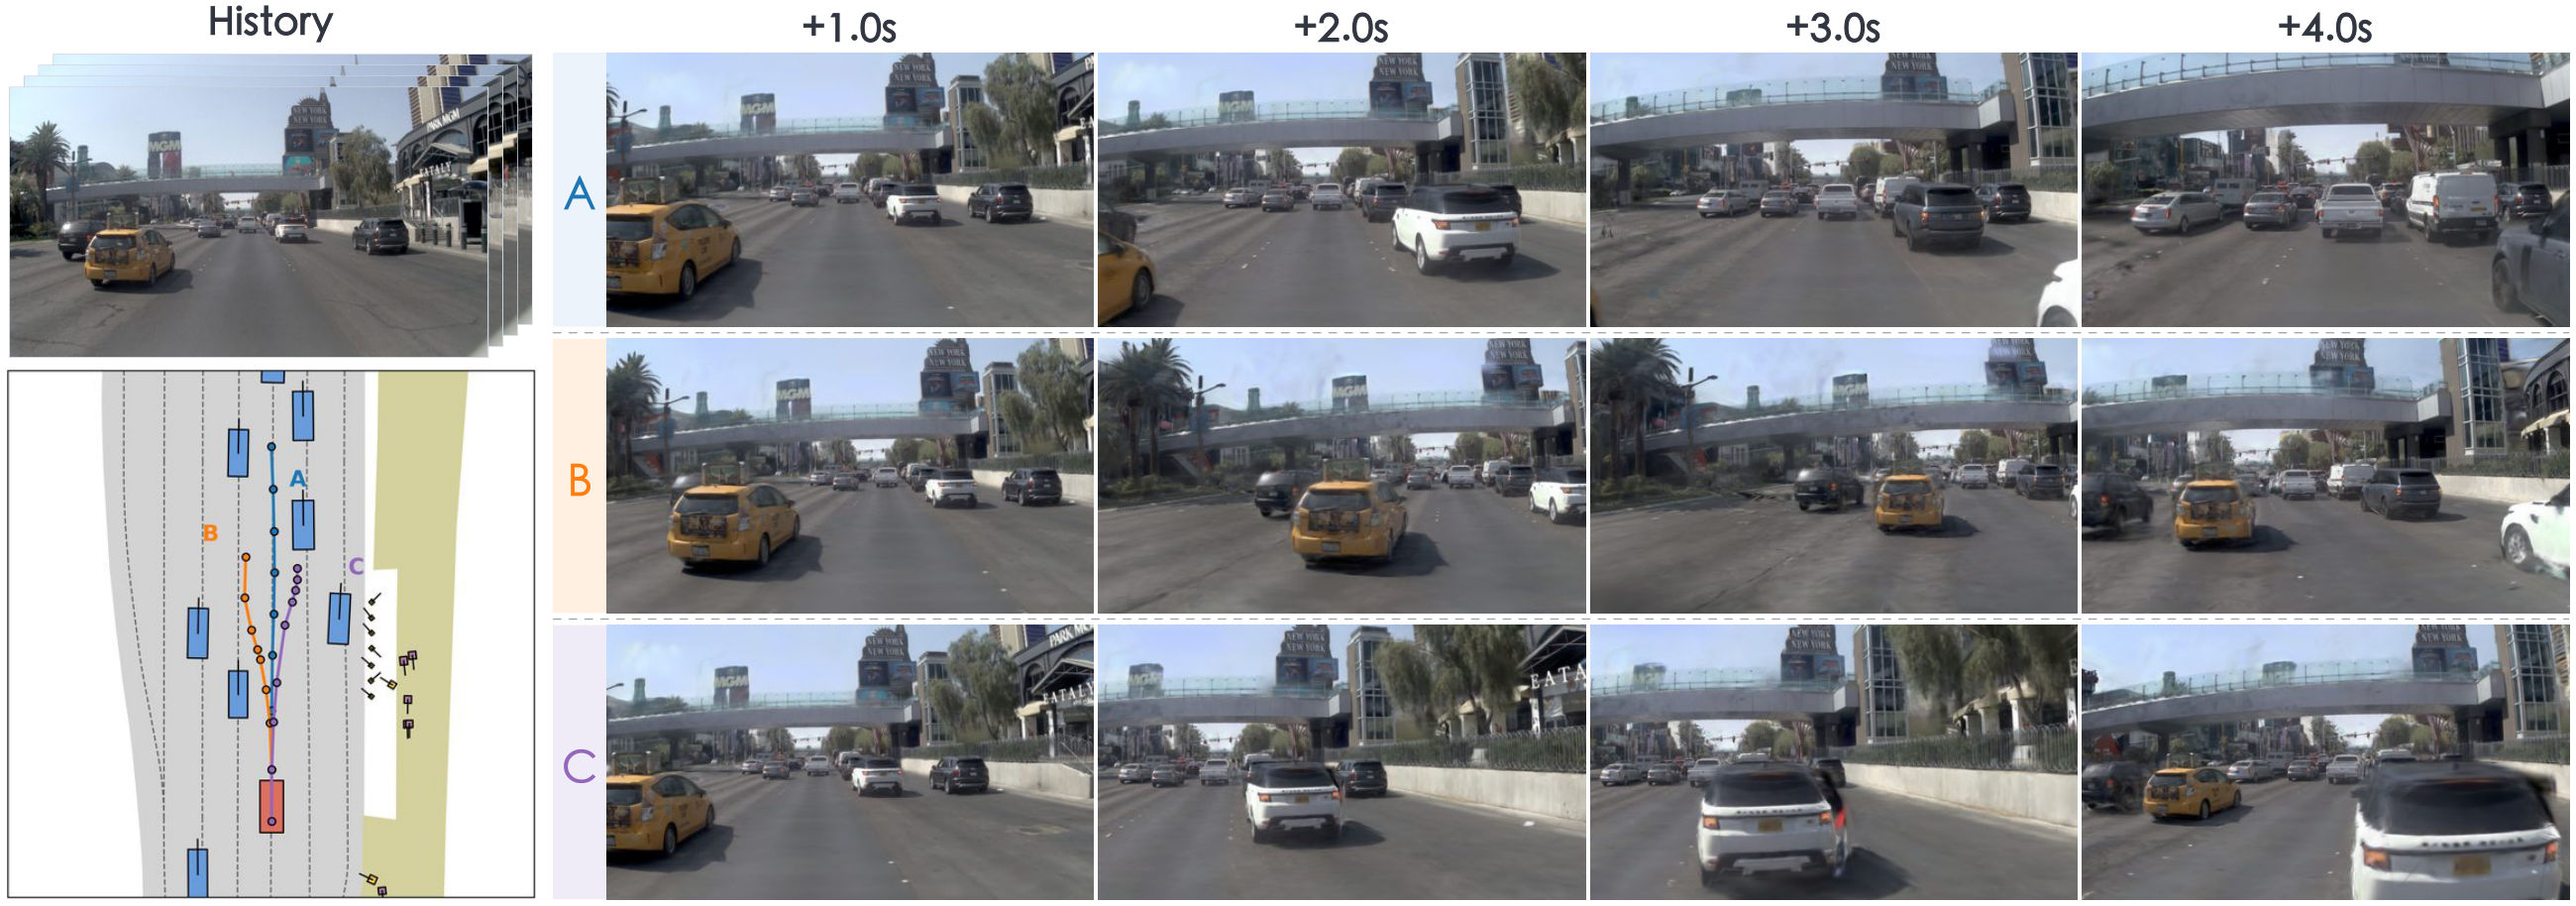
Simulator-rendered futures for going straight (A), changing lanes left (B), and changing lanes right (C).
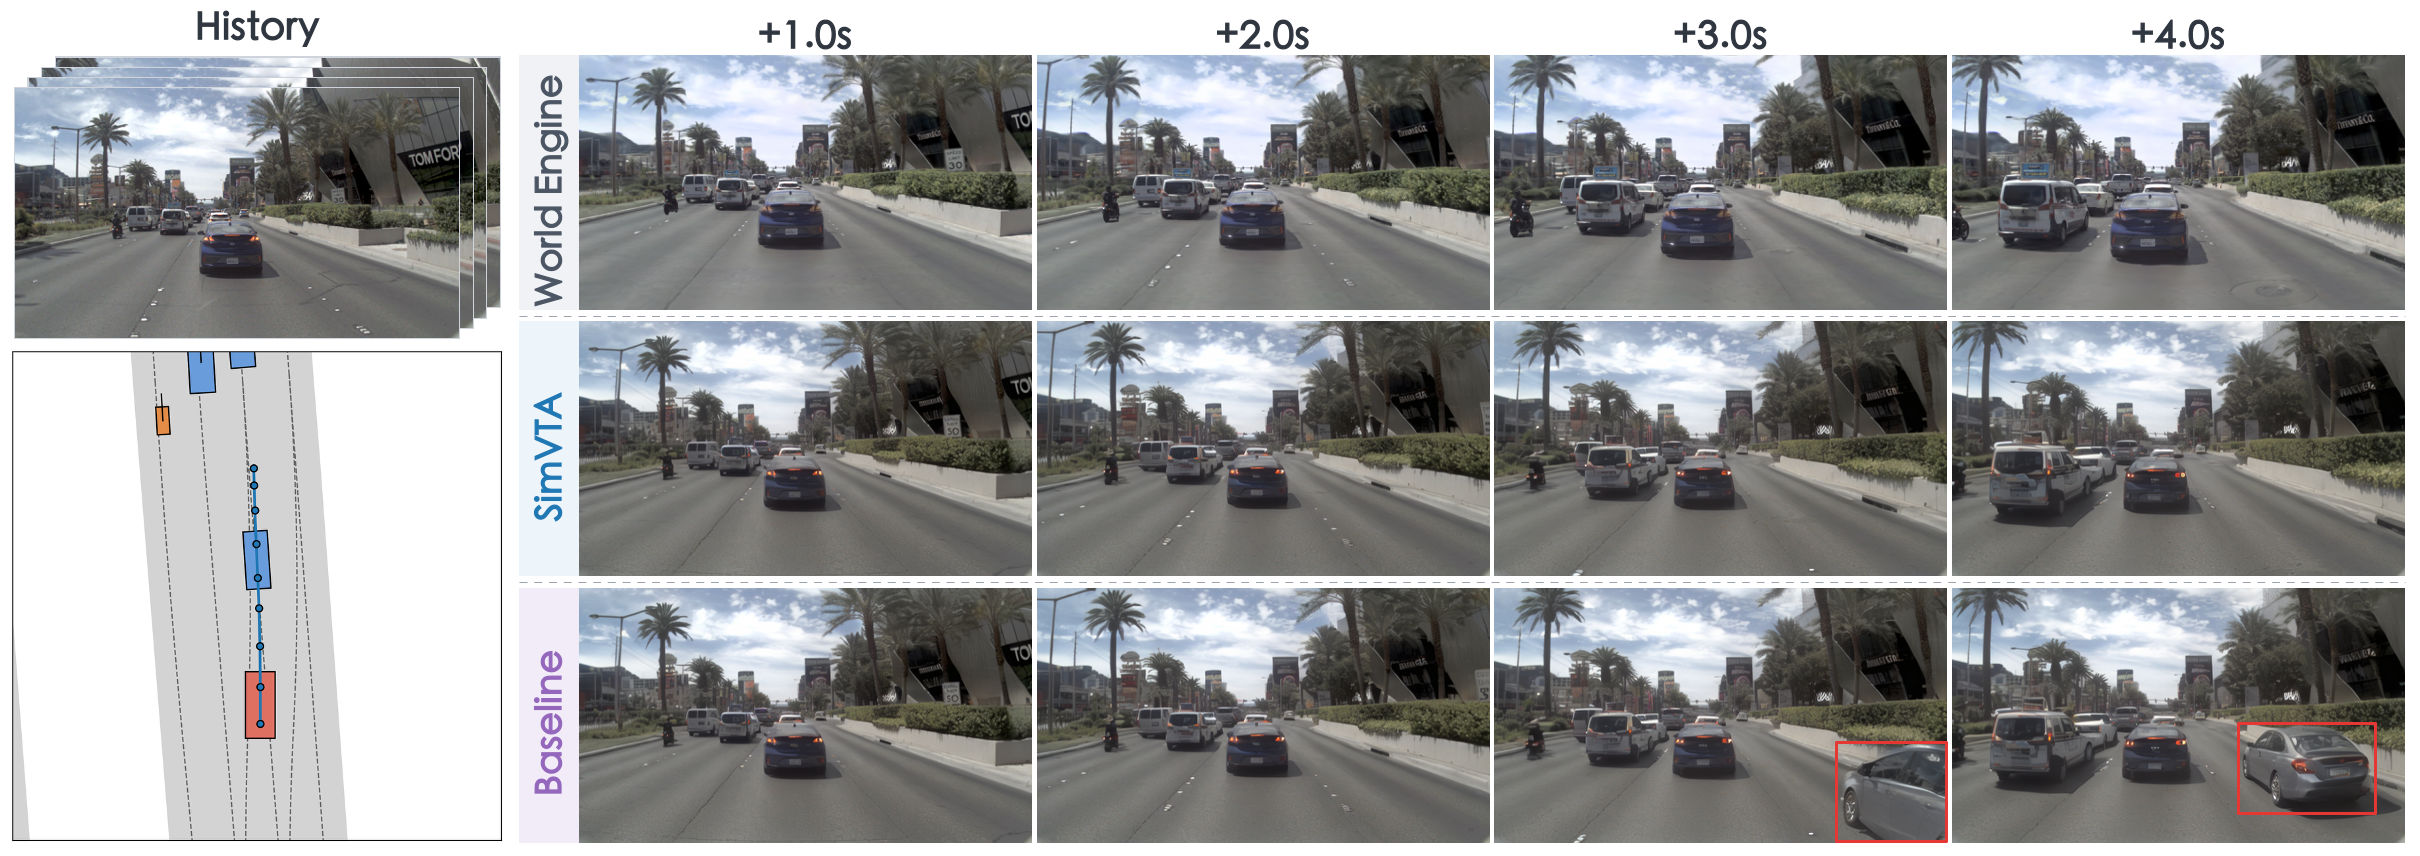
Video-trajectory alignment: World Engine renderings compared with SimVTA and Epona predictions.
We thank the authors and open-source contributors of the following projects for providing the models, simulation tools, and evaluation benchmarks that support this work:
- Epona | World Engine | NAVSIM | HUGSIM
We also thank the broader open-source community for its contributions to driving world models, autonomous driving, and 3D Gaussian Splatting.
All content in this repository is licensed under the Apache-2.0 license.
If our paper or code helps your research, please consider citing our work and giving this repository a star.